Robotics & control engineering

I build systems that help machines perceive, decide & move.

I’m Kyaw Hein Tun, a robotics system development engineer focused on modern control, autonomous systems, and practical robot software.

Navigating a changing career journey A path moves through mechatronics at YTU, robotics in Japan, and Munich at TUM, navigating around uncertainty, change, and constraints toward a future goal. CHANGE + RISK UNCERTAINTY CONSTRAINTS START MECHATRONICS YTU ROBOTICS JAPAN MUNICH / TUM I AM HERE LEARN→ ADAPT→ BUILD→ MOVE FORWARD
BASEMunich, Germany
FOCUSAutonomous Systems
TOOLKITROS 2 · C++ · Python
ROBOT CONTROL✦AUTONOMOUS NAVIGATION✦ ROS 2✦MECHATRONICS✦ ROBOT CONTROL✦AUTONOMOUS NAVIGATION✦ ROS 2✦MECHATRONICS✦

GUIDING IDEAS

Ideas I return to.

We can only see a short distance ahead, but we can see plenty there that needs to be done.

Alan Turing ↗ Computing Machinery and Intelligence · 1950

I was taught that the way of progress was neither swift nor easy.

Marie Curie ↗ A life devoted to scientific discovery

01 / SELECTED WORK

Engineering through experimentation.

Selected research, professional, and open-source work across autonomous navigation, perception, control, and robotic manipulation.

PROJECT / 01

Robotic Calligraphy

A ROS 2 robotic calligraphy system that converts Burmese, English, and Japanese characters into ordered robot trajectories using OpenCV, with pen-lift motion, KUKA-style IK tracking, and RViz visualization.

ROS 2PythonOpenCVInverse Kinematics
View repository ↗
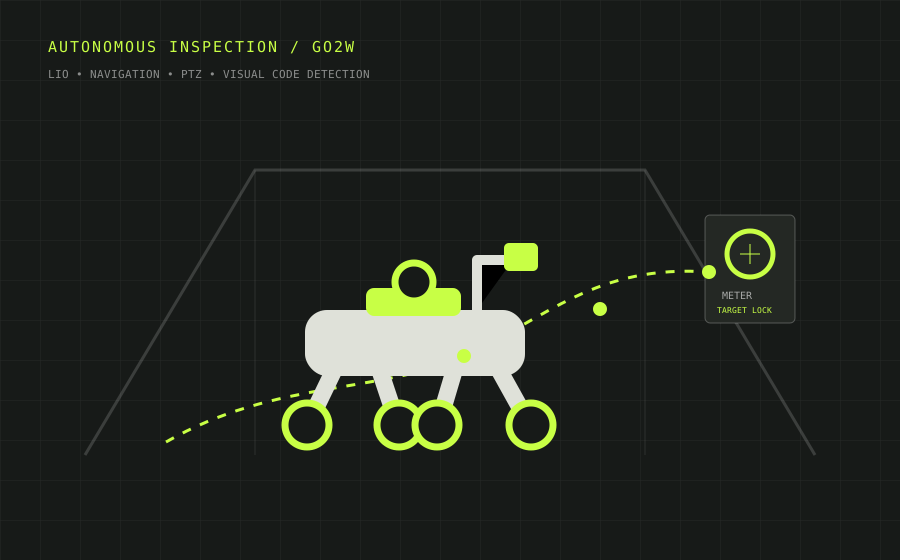
System diagram of a Unitree Go2W performing autonomous meter inspection with LiDAR and a PTZ camera
PROJECT / 02 · 2026

Autonomous Indoor Inspection

Integrated an autonomous inspection pipeline on a Unitree Go2W using BIEVR LIO, mission scheduling, navigation, PTZ camera control, and visual-code-guided meter inspection.

Unitree Go2WLiDARLIONavigation
Professional project · Qibitech
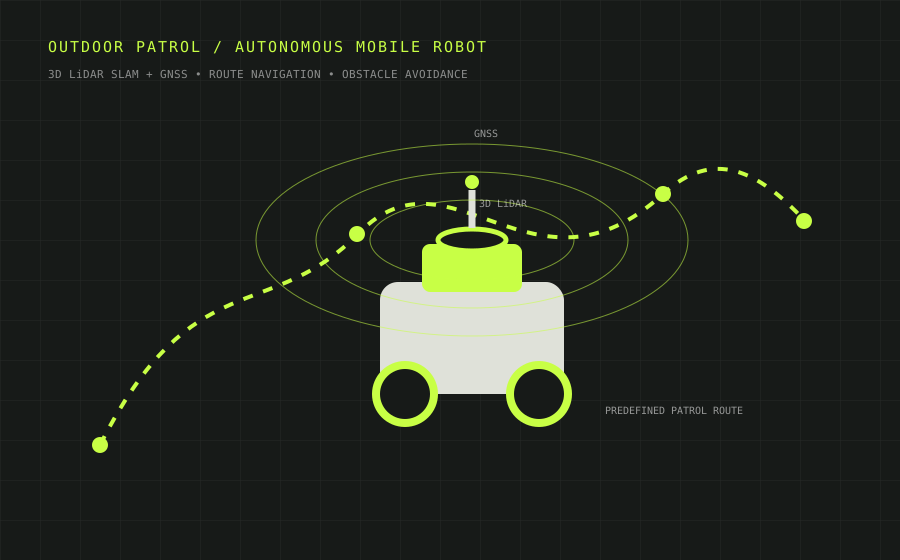
System diagram of an outdoor patrol robot using 3D LiDAR SLAM, GNSS, and route navigation
PROJECT / 03 · 2024—2025

Outdoor Patrol AMR

Developed autonomous campus patrol capabilities using 3D LiDAR SLAM with GNSS integration, predefined-route navigation, and obstacle avoidance.

3D LiDARSLAMGNSSPath Planning
Professional project · Qibitech
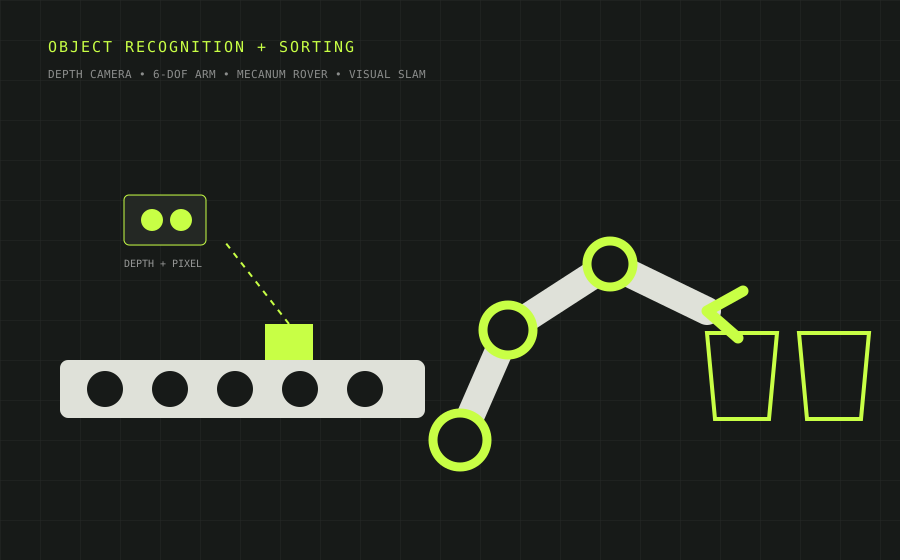
System diagram of a depth-camera-guided six-axis arm sorting conveyor objects from a mecanum rover
PROJECT / 04 · 2023

Object Recognition & Sorting

Built a demonstration system combining depth-based object localization, a 6-DOF arm, mecanum-rover transport, visual SLAM, and state-machine coordination. Presented at iREX 2023 in Tokyo.

Depth Camera6-DOF ArmVisual SLAMState Machine
Professional project · Qibitech
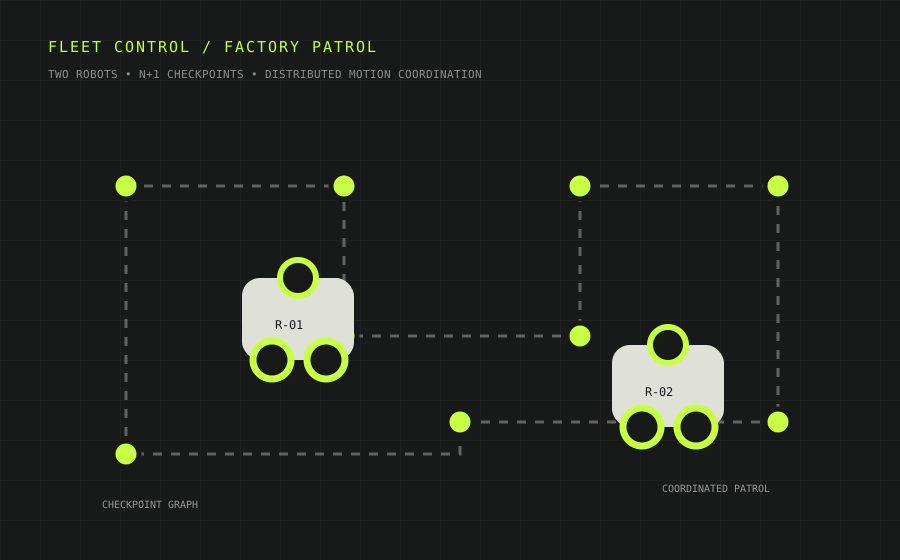
Diagram of two patrol robots coordinating motion over a distributed factory checkpoint network
PROJECT / 05 · 2022—2023

Fleet Control Experiment

Implemented and validated coordinated factory patrol with two mobile robots using an n+1-checkpoint distributed motion algorithm.

Fleet ControlMulti-RobotCoordinationPatrol
Professional project · Qibitech
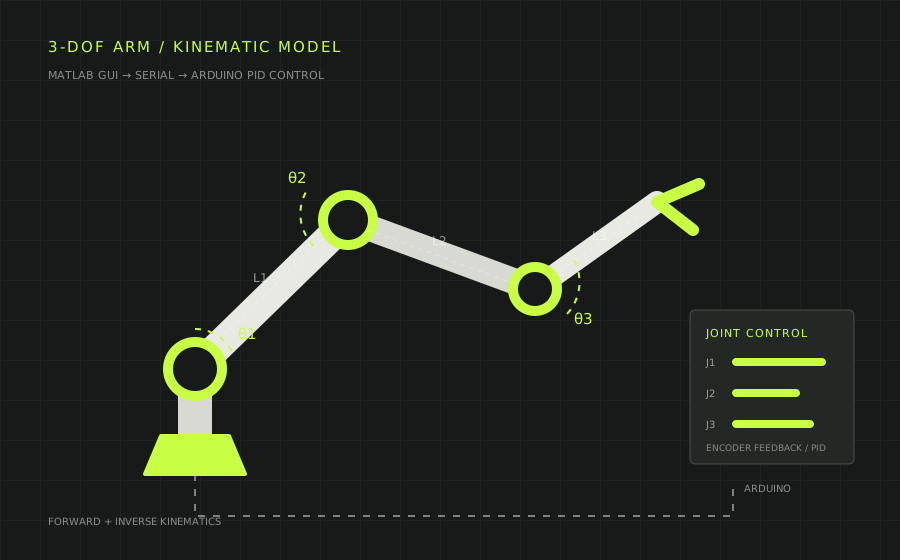
Technical diagram of the three-joint robotic arm and its MATLAB–Arduino control system
PROJECT / 06

Robotic Arm Control GUI

Developed manipulator control, forward and inverse kinematics, motion planning, and a MATLAB GUI integrated with Arduino hardware.

MATLABArduinoKinematicsMotion Planning
View repository ↗

02 / EXPERIENCE

From mechanical systems to intelligent machines.

01/10/2022 — 30/09/2026

Robotics Engineer

Qibitech Co., Ltd. ↗ · Tokyo, Japan

Integrated autonomous robotic systems and contributed across software design, development, testing, and deployment within a small international team.

01/02/2021 — 30/09/2022

NC Machine Operator, Design & Product Development

Toho Chikakoki Co., Ltd. ↗ · Fukuoka, Japan

Operated CNC machinery, checked dimensions and production quality, loaded raw materials, and performed periodic test runs.

31/12/2018 — 31/01/2019

Maintenance Engineer (Internship)

Myanmar Pharmaceutical Industry ↗ · Yangon, Myanmar

Supported the operation and maintenance of industrial equipment.

01/12/2016 — 30/11/2018

Assistant Trainer (Part-Time)

First Light Control Engineering Training Center · Yangon, Myanmar

Supported practical control-engineering training, including 3-DOF manipulator control, kinematics, motion planning, and GUI integration.

03 / ABOUT

Curiosity, translated into motion.

I’m a mechatronics engineer interested in making complex robotic behavior reliable, understandable, and useful.

My path spans hands-on maintenance, mechanical design, control engineering, and robotics software. That range helps me think about the complete system—not only the code.

01Robot softwareROS 2 · C++ · Python
02SimulationGazebo · MATLAB
03ControlMotion · Navigation
04HardwareArduino · Mechatronics
EDUCATION

IN PROGRESS

Master’s in Automotive Engineering

Technical University of Munich ↗

Focus: Autonomous Driving

Bachelor’s in Mechatronics, Robotics & Automation Engineering

Yangon Technological University ↗ · 2013–2019

LANGUAGES

Burmese · English · Japanese · German

CERTIFICATIONS

JLPT N2 · IELTS 7.5 · TOEIC 930

04 / CONTACT

Let’s make something
move.

Interested in robotics, autonomous systems, or engineering collaboration? Let’s connect.