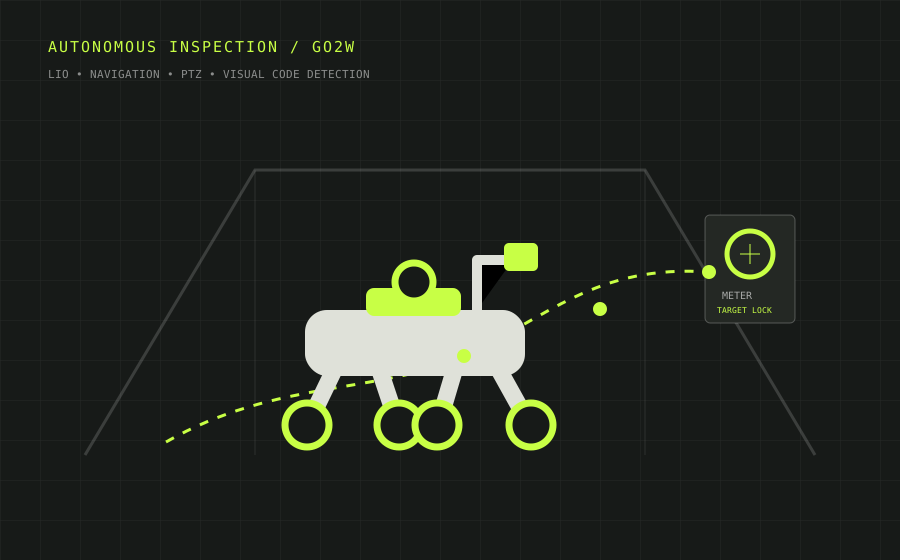
Autonomous Indoor Inspection
Integrated an autonomous inspection pipeline on a Unitree Go2W using BIEVR LIO, mission scheduling, navigation, PTZ camera control, and visual-code-guided meter inspection.
Robotics & control engineering
I’m Kyaw Hein Tun, a robotics system development engineer focused on modern control, autonomous systems, and practical robot software.
01 / SELECTED WORK
Selected research, professional, and open-source work across autonomous navigation, perception, control, and robotic manipulation.
A ROS 2 robotic calligraphy system that converts Burmese, English, and Japanese characters into ordered robot trajectories using OpenCV, with pen-lift motion, KUKA-style IK tracking, and RViz visualization.
Integrated an autonomous inspection pipeline on a Unitree Go2W using BIEVR LIO, mission scheduling, navigation, PTZ camera control, and visual-code-guided meter inspection.
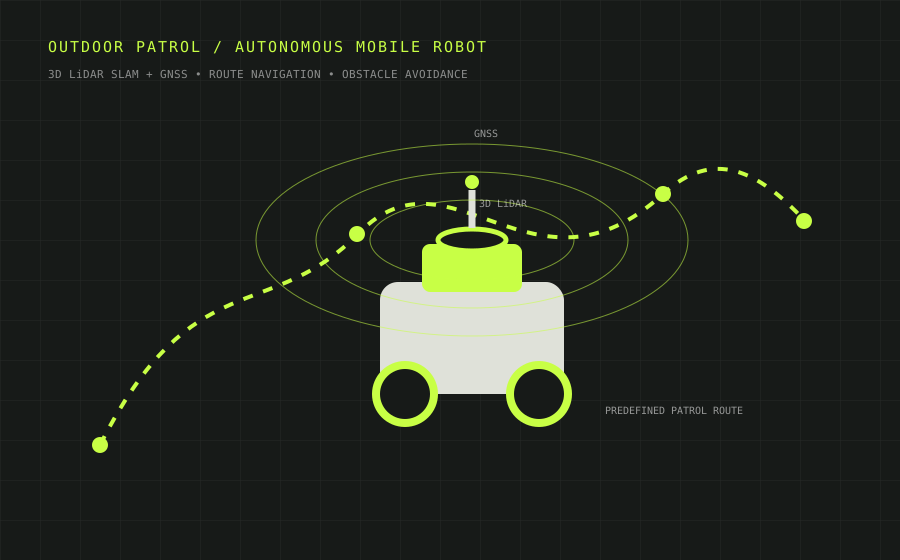
Developed autonomous campus patrol capabilities using 3D LiDAR SLAM with GNSS integration, predefined-route navigation, and obstacle avoidance.
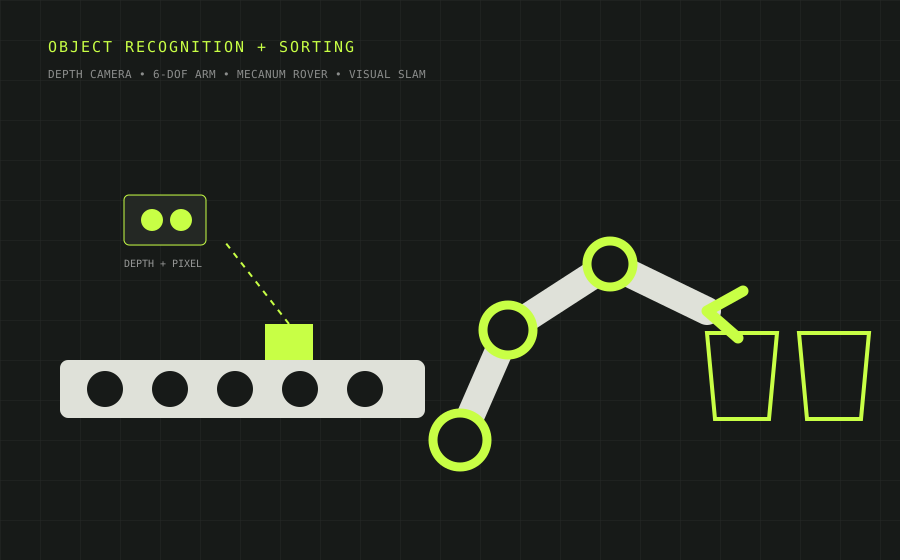
Built a demonstration system combining depth-based object localization, a 6-DOF arm, mecanum-rover transport, visual SLAM, and state-machine coordination. Presented at iREX 2023 in Tokyo.
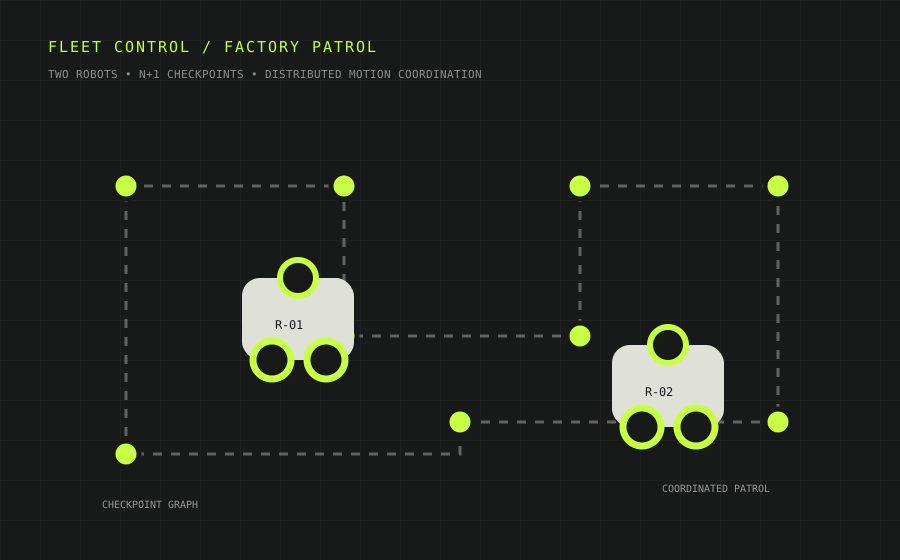
Implemented and validated coordinated factory patrol with two mobile robots using an n+1-checkpoint distributed motion algorithm.
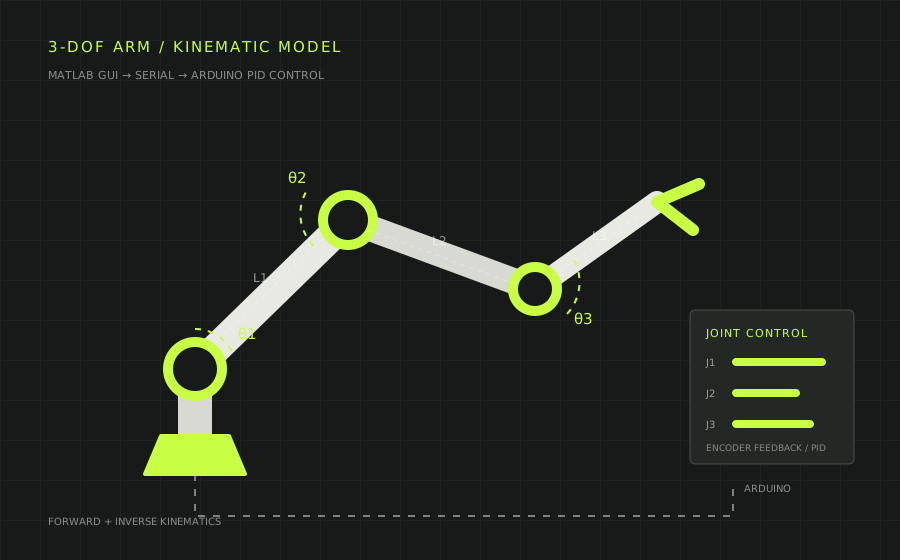
Developed manipulator control, forward and inverse kinematics, motion planning, and a MATLAB GUI integrated with Arduino hardware.
Graduation thesis enabling a 5-DOF manipulator to record and retrace human-demonstrated trajectories using gravity and friction compensation during teaching.
02 / EXPERIENCE
Kibitech Inc. · Tokyo, Japan
Developing robotic systems at the intersection of control engineering and software.
Toho Chikakoki Co., Ltd. · Fukuoka, Japan
Worked across CAD, design, and product development in an engineering environment.
Myanmar Pharmaceutical Industry · Yangon, Myanmar
Supported the operation and maintenance of industrial equipment.
First Light Control Engineering Training Center · Yangon
Supported practical learning in control engineering.
03 / ABOUT
I’m a mechatronics engineer interested in making complex robotic behavior reliable, understandable, and useful.
My path spans hands-on maintenance, mechanical design, control engineering, and robotics software. That range helps me think about the complete system—not only the code.
IN PROGRESS
Technical University of Munich
Focus: Autonomous Driving
Yangon Technological University · 2013–2019
Burmese · English · Japanese · German
JLPT N2 · IELTS 7.5 · TOEIC 930
04 / CONTACT
Interested in robotics, autonomous systems, or engineering collaboration? Let’s connect.